kornia.geometry.transform#
The functions in this section perform various geometric transformations of 2D and 3D images.
Warp operators#
- kornia.geometry.transform.warp_perspective(src, M, dsize, mode='bilinear', padding_mode='zeros', align_corners=True, fill_value=None)[source]#
Apply a perspective transformation to an image.
The function warp_perspective transforms the source image using the specified matrix:
\[\text{dst} (x, y) = \text{src} \left( \frac{M^{-1}_{11} x + M^{-1}_{12} y + M^{-1}_{13}}{M^{-1}_{31} x + M^{-1}_{32} y + M^{-1}_{33}} , \frac{M^{-1}_{21} x + M^{-1}_{22} y + M^{-1}_{23}}{M^{-1}_{31} x + M^{-1}_{32} y + M^{-1}_{33}} \right )\]- Convention:
See Conventions & Pitfalls for transform direction, pixel centres, normalized coordinates and
align_cornerssampling rules.input: \((B, C, H, W)\);
dsizeis(h, w)Mis the source→destination pixel homography \((B, 3, 3)\) (contrasthomography_warp(), which by default consumes destination→source normalized)a zero output dimension returns an autograd-connected empty tensor; negative output dimensions raise
ValueError
- Parameters:
src (
Tensor) – input image with shape \((B, C, H, W)\).M (
Tensor) – transformation matrix with shape \((B, 3, 3)\).dsize (
tuple[int,int]) – size of the output image (height, width).mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'|'fill'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:Truefill_value (
Optional[Tensor], optional) – torch.Tensor of shape \((3)\) that fills the padding area. Only supported for RGB. Default:None
- Return type:
- Returns:
the warped input image \((B, C, h, w)\), spatial sizes given by
dsize.
Example
>>> img = torch.rand(1, 4, 5, 6)
>>> H = torch.eye(3)[None]
>>> out = warp_perspective(img, H, (4, 2), align_corners=True)
>>> print(out.shape)
torch.Size([1, 4, 4, 2])
Note
This function is often used in conjunction with
get_perspective_transform().Note
See a working example here.
- kornia.geometry.transform.warp_perspective3d(src, M, dsize, flags='bilinear', border_mode='zeros', align_corners=False)[source]#
Apply a perspective transformation to an image.
The function warp_perspective transforms the source image using the specified matrix:
\[\text{dst}(x, y, z) = \text{src}\left( \pi\left( M^{-1} \cdot (x, y, z, 1)^{T} \right) \right)\]where \(\pi\) divides by the fourth (homogeneous) coordinate.
- Convention:
input: \((B, C, D, H, W)\);
dsizeis(d, h, w)Mis the source→destination pixel homography \((B, 4, 4)\)align_corners:
Falseby default (differs from the 2Dwarp_perspective(), whose default isTrue)border_mode:
'zeros'by defaulta zero output dimension returns an autograd-connected empty tensor; negative output dimensions raise
ValueError
- Parameters:
src (
Tensor) – input image with shape \((B, C, D, H, W)\).M (
Tensor) – transformation matrix with shape \((B, 4, 4)\).dsize (
tuple[int,int,int]) – size of the output image (depth, height, width).flags (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"border_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:False
- Return type:
- Returns:
the warped input image \((B, C, d, h, w)\), spatial sizes given by
dsize.
Note
This function is often used in conjunction with
get_perspective_transform3d().
- kornia.geometry.transform.warp_affine(src, M, dsize, mode='bilinear', padding_mode='zeros', align_corners=True, fill_value=None)[source]#
Apply an affine transformation to a torch.Tensor.
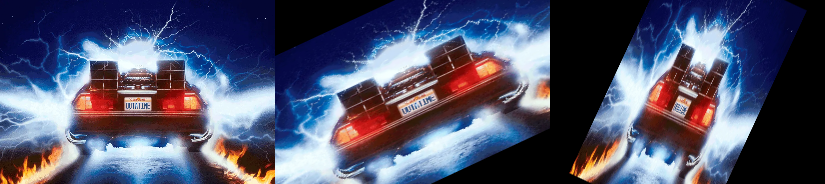
The function warp_affine transforms the source torch.Tensor using the specified matrix:
\[\text{dst}(x, y) = \text{src} \left( M^{-1}_{11} x + M^{-1}_{12} y + M^{-1}_{13} , M^{-1}_{21} x + M^{-1}_{22} y + M^{-1}_{23} \right )\]where \(M^{-1}\) is the inverse of the \(3 \times 3\) homogeneous extension of
M.- Convention:
See Conventions & Pitfalls for transform direction, pixel centres, normalized coordinates and
align_cornerssampling rules.input: \((B, C, H, W)\);
dsizeis(h, w)Mis the source→destination pixel affine matrix \((B, 2, 3)\)a zero output dimension returns an autograd-connected empty tensor; negative output dimensions raise
ValueError
- Parameters:
src (
Tensor) – input torch.Tensor of shape \((B, C, H, W)\).M (
Tensor) – affine transformation of shape \((B, 2, 3)\).dsize (
tuple[int,int]) – size of the output image (height, width).mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'|'fill'. Default:"zeros"align_corners (
bool, optional) – mode for grid_generation. Default:Truefill_value (
Optional[Tensor], optional) – torch.Tensor of shape \((C)\) or \((1)\) that fills the padding area. Default:None
- Return type:
- Returns:
the warped torch.Tensor with shape \((B, C, h, w)\), spatial sizes given by
dsize.
Note
This function is often used in conjunction with
get_rotation_matrix2d(),get_shear_matrix2d(),get_affine_matrix2d(),invert_affine_transform().Note
See a working example here.
Example
>>> img = torch.rand(1, 4, 5, 6)
>>> A = torch.eye(2, 3)[None]
>>> out = warp_affine(img, A, (4, 2), align_corners=True)
>>> print(out.shape)
torch.Size([1, 4, 4, 2])
- kornia.geometry.transform.warp_affine3d(src, M, dsize, flags='bilinear', padding_mode='zeros', align_corners=True)[source]#
Apply a projective transformation a to 3d torch.Tensor.
Warning
This API signature it is experimental and might suffer some changes in the future.
- Convention:
input: \((B, C, D, H, W)\);
dsizeis(d, h, w)Mis the source→destination pixel affine matrix \((B, 3, 4)\)align_corners:
Trueby defaultpadding_mode:
'zeros'by defaulta zero output dimension returns an autograd-connected empty tensor; negative output dimensions raise
ValueError
- Parameters:
src (
Tensor) – input torch.Tensor of shape \((B, C, D, H, W)\).M (
Tensor) – projective transformation matrix of shape \((B, 3, 4)\).dsize (
tuple[int,int,int]) – size of the output image (depth, height, width).flags (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – mode for grid_generation. Default:True
- Returns:
the warped 3d torch.tensor with shape \((B, C, d, h, w)\), spatial sizes given by
dsize.- Return type:
Note
This function is often used in conjunction with
get_perspective_transform3d().
- kornia.geometry.transform.warp_image_tps(image, kernel_centers, kernel_weights, affine_weights, align_corners=False, padding_mode='zeros')[source]#
Warp an image torch.Tensor according to the thin plate spline transform defined by arguments.
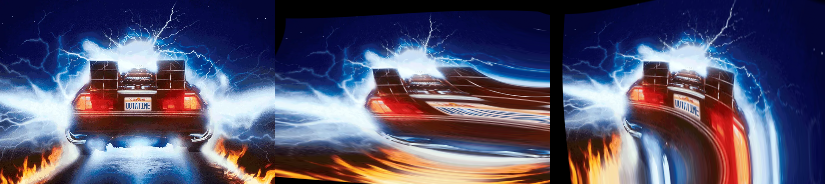
The transform is applied to each pixel coordinate in the output image to obtain a point in the input image for interpolation of the output pixel. So the TPS parameters should correspond to a warp from output space to input space.
The input image is a \((B, C, H, W)\) torch.Tensor. The kernel centers, kernel weight and affine weights are the same as in warp_points_tps.
- Convention:
image: \((B, C, H, W)\); the weights come from
get_tps_transform()called reversed,get_tps_transform(points_dst, points_src), andkernel_centersispoints_src(see its Convention block)all control points live in the normalized
grid_sampleframe selected byalign_corners: the half-pixel \(x_{norm} = (2x+1)/W - 1\) at the defaultFalse, the corner-aligned \(x_{norm} = 2x/(W-1) - 1\) atTrue; values outside \([-1, 1]\) sample the padding. Pixel-space control points silently give a wrong warp of the right shapealign_corners:
Falseby default (the matrix warps default toTrue)
- Parameters:
image (
Tensor) – input image torch.Tensor \((B, C, H, W)\).kernel_centers (
Tensor) – kernel center points \((B, K, 2)\).kernel_weights (
Tensor) – torch.Tensor of kernel weights \((B, K, 2)\).affine_weights (
Tensor) – torch.Tensor of affine weights \((B, 3, 2)\).align_corners (
bool, optional) – interpolation flag used by grid_sample. Default:Falsepadding_mode (
str, optional) – padding flag used by grid_sample. Default:"zeros"
- Return type:
- Returns:
warped image torch.Tensor \((B, C, H, W)\).
Example
>>> points_src = torch.rand(1, 5, 2)
>>> points_dst = torch.rand(1, 5, 2)
>>> image = torch.rand(1, 3, 32, 32)
>>> # note that we are getting the reverse transform: dst -> src
>>> kernel_weights, affine_weights = get_tps_transform(points_dst, points_src)
>>> warped_image = warp_image_tps(image, points_src, kernel_weights, affine_weights)
Note
This function is often used in conjunction with
get_tps_transform().
- kornia.geometry.transform.warp_points_tps(points_src, kernel_centers, kernel_weights, affine_weights)[source]#
Warp a torch.Tensor of coordinate points using the thin plate spline defined by arguments.
The source points should be a \((B, N, 2)\) torch.Tensor of \((x, y)\) coordinates. The kernel centers are a \((B, K, 2)\) torch.Tensor of \((x, y)\) coordinates. The kernel weights are a \((B, K, 2)\) torch.Tensor, and the affine weights are a \((B, 3, 2)\) torch.Tensor. For the weight tensors, torch.Tensor[…, 0] contains the weights for the x-transform and torch.Tensor[…, 1] the weights for the y-transform.
- Convention:
points: \((B, N, 2)\) (or \((B, K, 2)\) for kernel centers) in
(x, y)order; no normalization is applied, and the output is in the same frame, not clampedkernel_centersmust be the second argument passed toget_tps_transform()(see its Convention block)
- Parameters:
- Return type:
- Returns:
The \((B, N, 2)\) torch.Tensor of warped source points, from applying the TPS transform.
Example
>>> points_src = torch.rand(1, 5, 2)
>>> points_dst = torch.rand(1, 5, 2)
>>> kernel_weights, affine_weights = get_tps_transform(points_src, points_dst)
>>> warped = warp_points_tps(points_src, points_dst, kernel_weights, affine_weights)
>>> warped_correct = torch.allclose(warped, points_dst)
Note
This function is often used in conjunction with
get_tps_transform().
- kornia.geometry.transform.warp_grid(grid, src_homo_dst)[source]#
Compute the grid to warp the coordinates grid by the homography/ies.
- Convention:
gridcoordinates:(x, y)(last dim), shape \((1, H, W, 2)\) or \((N, H, W, 2)\)src_homo_dstis the destination→source homography \((1, 3, 3)\), \((N, 3, 3)\) or \((N, 1, 3, 3)\)only the \((1, H, W, 2)\) grid broadcasts over homography batches; a batched grid requires a matching batch of \(N\) homographies
- Parameters:
grid (
Tensor) – Unwrapped grid of the shape \((1, H, W, 2)\), or \((N, H, W, 2)\) with a matching batch of \(N\) homographies.src_homo_dst (
Tensor) – Homography or homographies (stacked) to transform all points in the grid. Shape of the homography has to be \((1, 3, 3)\), \((N, 3, 3)\) or \((N, 1, 3, 3)\).
- Return type:
- Returns:
the transformed grid of shape \((N, H, W, 2)\).
- kornia.geometry.transform.warp_grid3d(grid, src_homo_dst)[source]#
Compute the grid to warp the coordinates grid by the homography/ies.
- Convention:
gridcoordinates:(x, y, z)(last dim), shape \((1, D, H, W, 3)\) or \((N, D, H, W, 3)\)src_homo_dstis the destination→source homography \((1, 4, 4)\), \((N, 4, 4)\) or \((N, 1, 4, 4)\)only the \((1, D, H, W, 3)\) grid broadcasts over homography batches; a batched grid requires a matching batch of \(N\) homographies
- Parameters:
grid (
Tensor) – Unwrapped grid of the shape \((1, D, H, W, 3)\), or \((N, D, H, W, 3)\) with a matching batch of \(N\) homographies.src_homo_dst (
Tensor) – Homography or homographies (stacked) to transform all points in the grid. Shape of the homography has to be \((1, 4, 4)\), \((N, 4, 4)\) or \((N, 1, 4, 4)\).
- Return type:
- Returns:
the transformed grid of shape \((N, D, H, W, 3)\).
- kornia.geometry.transform.remap(image, map_x, map_y, mode='bilinear', padding_mode='zeros', align_corners=None, normalized_coordinates=False)[source]#
Apply a generic geometrical transformation to an image torch.Tensor.
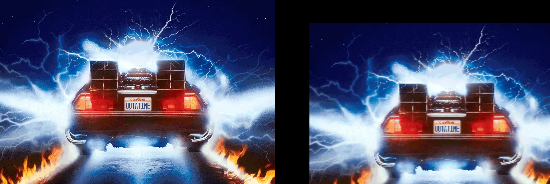
The function remap transforms the source torch.Tensor using the specified map:
\[\text{dst}(x, y) = \text{src}(map_x(x, y), map_y(x, y))\]- Convention:
input: \((B, C, H, W)\);
map_x/map_yare \((B, H, W)\) pixel coordinates unlessnormalized_coordinates=Truealign_corners:
Noneby default, resolved toFalseinternallypixel maps are normalized with the
align_corners=Trueconvention whatever flag reachesgrid_sample, so atFalse/Noneeven an identity map resamples the image; passalign_corners=True(#4504)the output spatial size comes from the maps; a zero map axis returns an autograd-connected empty output, including when the matching source axis is empty
- Parameters:
image (
Tensor) – the torch.Tensor to remap with shape (B, C, H, W). Where C is the number of channels.map_x (
Tensor) – the flow in the x-direction in pixel coordinates. The torch.Tensor must be in the shape of (B, H, W).map_y (
Tensor) – the flow in the y-direction in pixel coordinates. The torch.Tensor must be in the shape of (B, H, W).mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
Optional[bool], optional) – mode for grid_generation. Default:Nonenormalized_coordinates (
bool, optional) – whether the input coordinates are normalized in the range of [-1, 1]. Default:False
- Return type:
- Returns:
the warped torch.Tensor with same shape as the input grid maps.
Example
>>> import torch
>>> from kornia.geometry import create_meshgrid
>>> grid = create_meshgrid(2, 2, False)  # 1x2x2x2
>>> grid += 1  # apply offset in both directions
>>> input = torch.ones(1, 1, 2, 2)
>>> remap(input, grid[..., 0], grid[..., 1], align_corners=True)   # 1x1x2x2
tensor([[[[1., 0.],
          [0., 0.]]]])
Note
This function is often used in conjunction with
kornia.geometry.grid.create_meshgrid().
- kornia.geometry.transform.homography_warp(patch_src, src_homo_dst, dsize, mode='bilinear', padding_mode='zeros', align_corners=False, normalized_coordinates=True, normalized_homography=True)[source]#
Warp image patches or tensors by normalized 2D homographies.
See
HomographyWarperfor details.- Convention:
See Conventions & Pitfalls for homography direction, normalized coordinates and
align_cornerssampling rules.input: \((N, C, H, W)\)
src_homo_dstis the destination→source homography \((N, 3, 3)\), in normalized \([-1, 1]\) coordinates by default (normalized_coordinates=True), whennormalized_homography=True(default); withnormalized_homography=Falseit is consumed as the source→destination pixel homography, exactly likewarp_perspective()dsizeis(h, w)align_corners:
Falseby default (differs fromwarp_perspective())with
normalized_homography=False,modeandalign_cornersare ignored and'bilinear'/Trueare used (#4772)negative output dimensions raise
ValueError
- Parameters:
patch_src (
Tensor) – The image or torch.Tensor to warp. Should be from source of shape \((N, C, H, W)\).src_homo_dst (
Tensor) – The homography or torch.stack of homographies of shape \((N, 3, 3)\) — destination to source whennormalized_homography=True(default), source to destination (pixel) whennormalized_homography=False.dsize (
tuple[int,int]) – if homography normalized: The height and width of the image to warp. if homography not normalized: size of the output image (height, width).mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:Falsenormalized_coordinates (
bool, optional) – Whether the homography assumes [-1, 1] normalized coordinates or not. Default:Truenormalized_homography (
bool, optional) – whethersrc_homo_dstis a normalized (destination→source) homography (True, default) or a pixel source→destination homography (False). Default:True
- Return type:
- Returns:
Patch sampled at locations from source to destination.
Example
>>> input = torch.rand(1, 3, 32, 32)
>>> homography = torch.eye(3).view(1, 3, 3)
>>> output = homography_warp(input, homography, (32, 32))
Example
>>> img = torch.rand(1, 4, 5, 6)
>>> H = torch.eye(3)[None]
>>> out = homography_warp(img, H, (4, 2), align_corners=True, normalized_homography=False)
>>> print(out.shape)
torch.Size([1, 4, 4, 2])
- kornia.geometry.transform.homography_warp3d(patch_src, src_homo_dst, dsize, mode='bilinear', padding_mode='zeros', align_corners=False, normalized_coordinates=True)[source]#
Warp image patches or tensors by normalized 3D homographies.
- Convention:
input: \((N, C, D, H, W)\);
dsizeis(d, h, w)src_homo_dstis the destination→source homography \((N, 4, 4)\), in normalized \([-1, 1]\) coordinates by default (normalized_coordinates=True), and acts on(x, y, z, 1)column vectors:xindexesW,yindexesH,zindexesD. That is the ordertorch.nn.functional.grid_sample()reads a 5-D grid in, and the orderwarp_grid3d()takes. kornia’s own 3-D grids and pixel coordinates are(d, x, y)(seecreate_meshgrid3d()), so the sampling grid is reordered here before the homography is applied; nothing else in the module changes its orderalign_corners:
Falseby defaultpadding_mode:
'zeros'by defaultnegative output dimensions raise
ValueError
- Parameters:
patch_src (
Tensor) – The image or torch.Tensor to warp. Should be from source of shape \((N, C, D, H, W)\).src_homo_dst (
Tensor) – The homography or torch.stack of homographies from destination to source of shape \((N, 4, 4)\).dsize (
tuple[int,int,int]) – The depth, height and width of the volume to warp.mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:Falsenormalized_coordinates (
bool, optional) – Whether the homography assumes [-1, 1] normalized coordinates or not. Default:True
- Return type:
- Returns:
Patch sampled at locations from source to destination.
Example
>>> input = torch.rand(1, 3, 8, 32, 32)
>>> homography = torch.eye(4).view(1, 4, 4)
>>> output = homography_warp3d(input, homography, (8, 32, 32))
Image 2D transforms#
- kornia.geometry.transform.affine(tensor, matrix, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Apply an affine transformation to the image.
- Convention:
See Conventions & Pitfalls for the
align_cornersdefaults and sampling rules.matrixis the source→destination pixel affine matrix \((B, 2, 3)\)
- Parameters:
tensor (
Tensor) – The image tensor to be warped in shapes of \((C, H, W)\) or \((B, C, H, W)\).matrix (
Tensor) – The 2x3 affine transformation matrix.mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:True
- Return type:
- Returns:
The warped image with the same shape as the input.
Example
>>> img = torch.rand(1, 2, 3, 5)
>>> aff = torch.eye(2, 3)[None]
>>> out = affine(img, aff)
>>> print(out.shape)
torch.Size([1, 2, 3, 5])
- kornia.geometry.transform.rotate(tensor, angle, center=None, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Rotate the tensor anti-clockwise about the center.
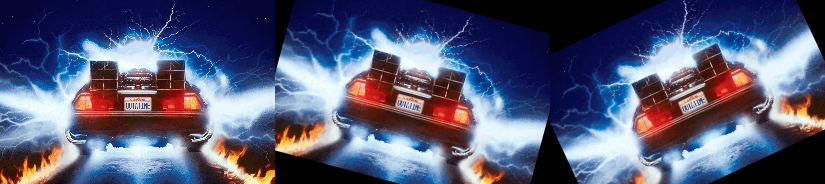
- Convention:
centeris(x, y)in pixels, origin at top-left; defaults to the tensor centerpositive
anglerotates counter-clockwise as displayed (y-down image axes)
- Parameters:
tensor (
Tensor) – The image tensor to be warped in shapes of \((B, C, H, W)\).angle (
Tensor) – The angle through which to rotate. The tensor must have a shape of (B), where B is batch size.center (
Optional[Tensor], optional) – The center through which to rotate. The tensor must have a shape of (B, 2), where B is batch size and last dimension contains cx and cy. Default:Nonemode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:True
- Return type:
- Returns:
The rotated tensor with shape as input.
Note
See a working example here.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> angle = torch.tensor([90.])
>>> out = rotate(img, angle)
>>> print(out.shape)
torch.Size([1, 3, 4, 4])
- kornia.geometry.transform.translate(tensor, translation, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Translate the tensor in pixel units.
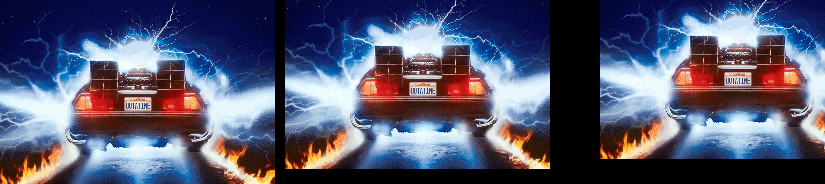
- Convention:
translationis(dx, dy)in pixels
- Parameters:
tensor (
Tensor) – The image tensor to be warped in shapes of \((B, C, H, W)\).translation (
Tensor) – tensor containing the amount of pixels to translate in the x and y direction. The tensor must have a shape of (B, 2), where B is batch size, last dimension contains dx dy.mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:True
- Return type:
- Returns:
The translated tensor with shape as input.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> translation = torch.tensor([[1., 0.]])
>>> out = translate(img, translation)
>>> print(out.shape)
torch.Size([1, 3, 4, 4])
- kornia.geometry.transform.scale(tensor, scale_factor, center=None, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Scale the tensor by a factor.
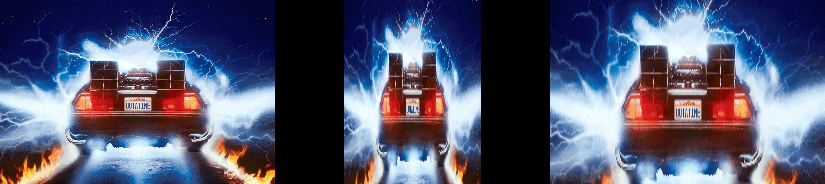
- Convention:
centeris(x, y)in pixels, origin at top-left; defaults to the tensor center
- Parameters:
tensor (
Tensor) – The image tensor to be warped in shapes of \((B, C, H, W)\).scale_factor (
Tensor) – The scale factor apply. The tensor must have a shape of (B) or (B, 2), where B is batch size. If (B), isotropic scaling will perform. If (B, 2), x-y-direction specific scaling will perform.center (
Optional[Tensor], optional) – The center through which to scale. The tensor must have a shape of (B, 2), where B is batch size and last dimension contains cx and cy. Default:Nonemode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:True
- Return type:
- Returns:
The scaled tensor with the same shape as the input.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> scale_factor = torch.tensor([[2., 2.]])
>>> out = scale(img, scale_factor)
>>> print(out.shape)
torch.Size([1, 3, 4, 4])
- kornia.geometry.transform.shear(tensor, shear, mode='bilinear', padding_mode='zeros', align_corners=False)[source]#
Shear the tensor.
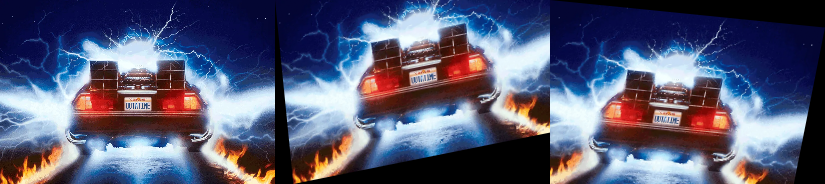
- Convention:
shearis(shx, shy)align_corners:
Falseby default (differs from the other 2D affine warps and fromShear, which default toTrue)
- Parameters:
tensor (
Tensor) – The image tensor to be skewed with shape of \((B, C, H, W)\).shear (
Tensor) – tensor containing the angle to shear in the x and y direction. The tensor must have a shape of (B, 2), where B is batch size, last dimension contains shx shy.mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:False
- Return type:
- Returns:
The skewed tensor with shape same as the input.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> shear_factor = torch.tensor([[0.5, 0.0]])
>>> out = shear(img, shear_factor)
>>> print(out.shape)
torch.Size([1, 3, 4, 4])
- kornia.geometry.transform.hflip(input)[source]#
Horizontally flip a torch.Tensor image or a batch of torch.Tensor images.
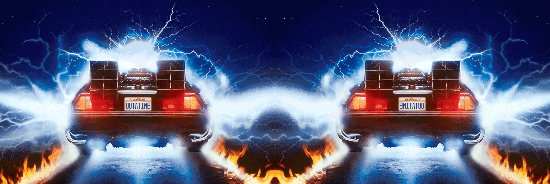
- Convention:
flips the last dimension (dim
-1); accepts any rank \(\geq 1\) (rank 0 is outside the contract)
- kornia.geometry.transform.vflip(input)[source]#
Vertically flip a torch.Tensor image or a batch of torch.Tensor images.
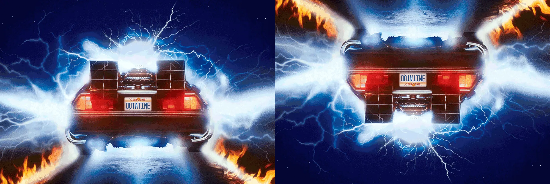
- Convention:
flips along the height axis (the second-to-last dimension)
requires rank ≥ 2 (operates on dim
-2): unbatched \((H, W)\)/ \((C, H, W)\) or batched \((*, C, H, W)\) all work
- kornia.geometry.transform.rot180(input)[source]#
Rotate a torch.Tensor image or a batch of torch.Tensor images 180 degrees.
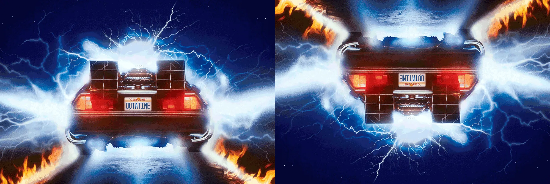
- Convention:
- kornia.geometry.transform.resize(input, size, interpolation='bilinear', align_corners=None, side='short', antialias=False)[source]#
Resize the input torch.Tensor to the given size.
- Convention:
See Conventions & Pitfalls for sampling and
align_cornersconventions. When resizing camera images, see camera and world conventions for matching intrinsics scaling.input: \((*, H, W)\);
sizeis(h, w)align_corners:
Noneby default (followstorch.nn.functional.interpolate; notewarp_perspective()/rotate()defaultTrue)sideresizing preserves aspect ratio using the named side
- Parameters:
input (
Tensor) – The image tensor to be skewed with shape of \((..., H, W)\). … means there can be any number of dimensions.size (
Union[int,Tuple[int,int]]) – Desired output size. If size is a sequence like (h, w), output size will be matched to this. If size is an int, smaller edge of the image will be matched to this number. i.e, if height > width, then image will be rescaled to (size * height / width, size)interpolation (
str, optional) – algorithm used for upsampling:'nearest'|'linear'|'bilinear'| ‘bicubic’ | ‘trilinear’ | ‘area’. Default:"bilinear"align_corners (
Optional[bool], optional) – interpolation flag. Default:Noneside (
str, optional) – Corresponding side ifsizeis an integer. Can be one of'short','long','vert', or'horz'. Default:"short"antialias (
bool, optional) – if True, then image will be filtered with Gaussian before downscaling. No effect for upscaling. Default:False
- Return type:
- Returns:
The resized tensor with the shape as the specified size.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> out = resize(img, (6, 8))
>>> print(out.shape)
torch.Size([1, 3, 6, 8])
- kornia.geometry.transform.resize_to_be_divisible(input, divisible_factor, interpolation='bilinear', align_corners=None, side='short', antialias=False)[source]#
Resize the input tensor to be divisible by a certain factor.
- Convention:
- Parameters:
input (torch.Tensor) – Input tensor to be resized.
divisible_factor (int) – The factor to which the image should be divisible.
interpolation (str, optional) – Interpolation flag. Defaults to “bilinear”. Default:
"bilinear"align_corners (Optional[bool], optional) – whether to align the corners of the input and output. Defaults to None. Default:
Noneside (str, optional) – Side to resize. Defaults to “short”. Default:
"short"antialias (bool, optional) – If True, then image will be filtered with Gaussian before downscaling. Defaults to False. Default:
False
- Returns:
The resized tensor.
- Return type:
- kornia.geometry.transform.rescale(input, factor, interpolation='bilinear', align_corners=None, antialias=False)[source]#
Rescale the input torch.Tensor with the given factor.
- Convention:
- Parameters:
input (
Tensor) – The image tensor to be scale with shape of \((B, C, H, W)\).factor (
Union[float,Tuple[float,float]]) – Desired scaling factor as(factor_h, factor_w)— height first. If a single float, the value is used for both height and width (anintraisesTypeError).interpolation (
str, optional) – algorithm used for upsampling:'nearest'|'linear'|'bilinear'|'bicubic'|'trilinear'|'area'. Default:"bilinear"align_corners (
Optional[bool], optional) – interpolation flag. Default:Noneantialias (
bool, optional) – if True, then image will be filtered with Gaussian before downscaling. No effect for upscaling. Default:False
- Return type:
- Returns:
The rescaled tensor with the shape as the specified size.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> out = rescale(img, (2, 3))
>>> print(out.shape)
torch.Size([1, 3, 8, 12])
- kornia.geometry.transform.elastic_transform2d(image, noise, kernel_size=(63, 63), sigma=(32.0, 32.0), alpha=(1.0, 1.0), align_corners=False, mode='bilinear', padding_mode='zeros')[source]#
Apply elastic transform of images as described in [SSP03].
- Convention:
image: \((B, C, H, W)\);
noise: \((B, 2, H, W)\) with channel 0 the x- and channel 1 the y-displacement of the sampling grid (positive x-noise shifts image content left)displacements are smoothed with a Gaussian (
kernel_size,sigma) and scaled byalphaalign_corners:
Falseby default (the matrix warps default toTrue); zeronoiseis an identity under either setting
- Parameters:
image (
Tensor) – Input image to be transformed with shape \((B, C, H, W)\).noise (
Tensor) – Noise image used to spatially transform the input image. Same resolution as the input image with shape \((B, 2, H, W)\). The coordinates order it is expected to be in x-y.kernel_size (
Tuple[int,int], optional) – the size of the Gaussian kernel, in the y and x directions, respectively. Default:(63, 63)sigma (
Union[Tuple[float,float],Tensor], optional) – The standard deviation of the Gaussian in the y and x directions, respectively. Larger sigma results in smaller pixel displacements. Default:(32.0, 32.0)alpha (
Union[Tuple[float,float],Tensor], optional) – The scaling factor that controls the intensity of the deformation in the x and y directions, respectively. Default:(1.0, 1.0)align_corners (
bool, optional) – Interpolation flag used bygrid_sample. Default:Falsemode (
str, optional) – Interpolation mode used bygrid_sample. Either'bilinear'or'nearest'. Default:"bilinear"padding_mode (
str, optional) – The padding used bygrid_sample. Either'zeros','border'or'reflection'. Default:"zeros"
- Return type:
- Returns:
the elastically transformed input image with shape \((B,C,H,W)\).
Example
>>> image = torch.rand(1, 3, 5, 5)
>>> noise = torch.rand(1, 2, 5, 5, requires_grad=True)
>>> image_hat = elastic_transform2d(image, noise, (3, 3))
>>> image_hat.mean().backward()
>>> image = torch.rand(1, 3, 5, 5)
>>> noise = torch.rand(1, 2, 5, 5)
>>> sigma = torch.tensor([4., 4.], requires_grad=True)
>>> image_hat = elastic_transform2d(image, noise, (3, 3), sigma)
>>> image_hat.mean().backward()
>>> image = torch.rand(1, 3, 5, 5)
>>> noise = torch.rand(1, 2, 5, 5)
>>> alpha = torch.tensor([16., 32.], requires_grad=True)
>>> image_hat = elastic_transform2d(image, noise, (3, 3), alpha=alpha)
>>> image_hat.mean().backward()
- kornia.geometry.transform.pyrdown(input, border_type='reflect', align_corners=False, factor=2.0)[source]#
Blur a torch.Tensor and downsamples it.
- Convention:
input: \((B, C, H, W)\)
output spatial size is
floor(side / factor)per dimension (\(5 \times 5 \to 2 \times 2\) at the defaultfactor=2.0— note OpenCV’spyrDownrounds up instead)border_type:
'reflect'by default (blur before downsample)align_corners:
Falseby default
- Parameters:
input (
Tensor) – the torch.Tensor to be downsampled.border_type (
str, optional) – the padding mode to be applied before convolving. The expected modes are:'constant','reflect','replicate'or'circular'. Default:"reflect"align_corners (
bool, optional) – interpolation flag. Default:Falsefactor (
float, optional) – the downsampling factor Default:2.0
- Return type:
- Returns:
the downsampled torch.Tensor.
Examples
>>> input = torch.arange(16, dtype=torch.float32).reshape(1, 1, 4, 4)
>>> pyrdown(input, align_corners=True)
tensor([[[[ 3.7500,  5.2500],
          [ 9.7500, 11.2500]]]])
- kornia.geometry.transform.pyrup(input, border_type='reflect', align_corners=False)[source]#
Upsample a torch.Tensor and then blurs it.
- Convention:
input: \((B, C, H, W)\)
output spatial size is exactly doubled per dimension (no
factorparameter, unlikepyrdown(); \(3 \times 3 \to 6 \times 6\))border_type:
'reflect'by default (blur after upsample)align_corners:
Falseby default
- Parameters:
- Return type:
- Returns:
the upsampled torch.Tensor.
Examples
>>> input = torch.arange(4, dtype=torch.float32).reshape(1, 1, 2, 2)
>>> pyrup(input, align_corners=True)
tensor([[[[0.7500, 0.8750, 1.1250, 1.2500],
          [1.0000, 1.1250, 1.3750, 1.5000],
          [1.5000, 1.6250, 1.8750, 2.0000],
          [1.7500, 1.8750, 2.1250, 2.2500]]]])
- kornia.geometry.transform.build_pyramid(input, max_level, border_type='reflect', align_corners=False)[source]#
Construct the Gaussian pyramid for a torch.Tensor image.
The function constructs a vector of images and builds the Gaussian pyramid by recursively applying pyrDown to the previously built pyramid layers.
- Convention:
input: \((B, C, H, W)\)
max_levelis the total number of levels returned (including the unchanged original as level 0), not a 0-based index of the last leveleach subsequent level is produced by
pyrdown()(floor(side / 2)per dimension)
Warning
The
max_levelbounds check does not currently reject non-positive integer values: passing an integermax_level <= 0returns the same single-element list asmax_level=1instead of raising. Tracked in #3927.- Parameters:
input (
Tensor) – the torch.Tensor to be used to construct the pyramid.max_level (
int) – the number of pyramid levels to return, including the unchanged original image as level 0.border_type (
str, optional) – the padding mode to be applied before convolving. The expected modes are:'constant','reflect','replicate'or'circular'. Default:"reflect"align_corners (
bool, optional) – interpolation flag. Default:False
- Return type:
- Shape:
Input: \((B, C, H, W)\)
Output \([(B, C, H, W), (B, C, H/2, W/2), ...]\)
- kornia.geometry.transform.build_laplacian_pyramid(input, max_level, border_type='reflect', align_corners=False)[source]#
Construct the Laplacian pyramid for a torch.Tensor image.
The function constructs a vector of images and builds the Laplacian pyramid by recursively computing the difference after applying pyrUp to the adjacent layer in its Gaussian pyramid.
See [BA87] for more details.
- Convention:
input: \((B, C, H, W)\)
max_levelis the total number of levels returned, not a 0-based index of the last levellevels
0throughmax_level - 2are band-pass residuals: leveli=build_pyramid()Gaussian leveliminus apyrup()-expanded Gaussian leveli + 1; only the last element (indexmax_level - 1) is the unsubtracted final Gaussian level — level 0 is not the unchanged original image whenevermax_level > 1the input is reflect-padded up to the next power of two (per dimension) only when neither the height nor the width is already a power of two; when it is applied, every returned level — including level 0 — is shaped from the padded size
border_type:
'reflect'by defaultalign_corners:
Falseby default
Warning
For a mixed odd/power-of-two input size (one dimension a power of two, the other not), no padding is applied and the level-to-level subtraction can raise
RuntimeErrorfrom a shape mismatch whenmax_level > 1(e.g. a \((1, 1, 5, 8)\) input withmax_level=2). This is likely unintended and tracked in #3927. Separately, themax_levelbounds check does not currently reject non-positive integer values: passing an integermax_level <= 0returns the same single-element list asmax_level=1instead of raising — also tracked in #3927.- Parameters:
input (
Tensor) – the torch.Tensor to be used to construct the pyramid with shape \((B, C, H, W)\).max_level (
int) – the number of pyramid levels to return (see Convention above for what each level contains).border_type (
str, optional) – the padding mode to be applied before convolving. The expected modes are:'constant','reflect','replicate'or'circular'. Default:"reflect"align_corners (
bool, optional) – interpolation flag. Default:False
- Returns:
\([(B, C, H', W'), (B, C, H'/2, W'/2), ...]\), where \((H', W')\) equals the input \((H, W)\) unless padding was applied (see Convention above), in which case it is the padded size.
- Return type:
Output
Image 3D transforms#
- kornia.geometry.transform.affine3d(tensor, matrix, mode='bilinear', padding_mode='zeros', align_corners=False)[source]#
Apply an affine transformation to the 3d volume.
- Convention:
matrixis the source→destination pixel affine matrix \((B, 3, 4)\)align_corners:
Falseby default (the 2Daffine()defaults toTrue)
- Parameters:
tensor (
Tensor) – The image tensor to be warped in shapes of \((C, D, H, W)\) or \((B, C, D, H, W)\).matrix (
Tensor) – The affine transformation matrix with shape \((B, 3, 4)\).mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values `` ‘zeros’`` |'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:False
- Return type:
- Returns:
The warped image.
Example
>>> img = torch.rand(1, 2, 4, 3, 5)
>>> aff = torch.eye(3, 4)[None]
>>> out = affine3d(img, aff)
>>> print(out.shape)
torch.Size([1, 2, 4, 3, 5])
- kornia.geometry.transform.rotate3d(tensor, yaw, pitch, roll, center=None, mode='bilinear', padding_mode='zeros', align_corners=False)[source]#
Rotate 3D the tensor anti-clockwise about the centre.
- Convention:
centeris(x, y, z)in pixels, origin at the top-left of the first depth slice (z = 0); defaults to the tensor centeralign_corners:
Falseby default (the 2Drotate()defaults toTrue)
- Parameters:
tensor (
Tensor) – The image tensor to be warped in shapes of \((B, C, D, H, W)\).yaw (
Tensor) – The yaw angle through which to rotate. The tensor must have a shape of (B), where B is batch size.pitch (
Tensor) – The pitch angle through which to rotate. The tensor must have a shape of (B), where B is batch size.roll (
Tensor) – The roll angle through which to rotate. The tensor must have a shape of (B), where B is batch size.center (
Optional[Tensor], optional) – The center through which to rotate. The tensor must have a shape of (B, 3), where B is batch size and last dimension contains x, y and z. Default:Nonemode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:False
- Returns:
The rotated tensor with shape as input.
- Return type:
Matrix transformations#
- kornia.geometry.transform.get_perspective_transform(points_src, points_dst)[source]#
Calculate a perspective transform from four pairs of the corresponding points.
The algorithm is a vanilla implementation of the Direct Linear transform (DLT). See more: https://www.cs.cmu.edu/~16385/s17/Slides/10.2_2D_Alignment__DLT.pdf
The function calculates the matrix of a perspective transform that maps from the source to destination points:
\[\begin{split}\begin{bmatrix} x^{'} \\ y^{'} \\ 1 \\ \end{bmatrix} = \begin{bmatrix} h_1 & h_2 & h_3 \\ h_4 & h_5 & h_6 \\ h_7 & h_8 & h_9 \\ \end{bmatrix} \cdot \begin{bmatrix} x \\ y \\ 1 \\ \end{bmatrix}\end{split}\]- Convention:
points:
(x, y), pixel centers, origin at top-left; shape \((B, 4, 2)\)returns the source→destination pixel homography \((B, 3, 3)\) that
warp_perspective()takes
- Parameters:
- Return type:
- Returns:
the perspective transformation with shape \((B, 3, 3)\).
Note
This function is often used in conjunction with
warp_perspective().Example
>>> x1 = torch.tensor([[[0., 0.], [1., 0.], [1., 1.], [0., 1.]]])
>>> x2 = torch.tensor([[[1., 0.], [0., 0.], [0., 1.], [1., 1.]]])
>>> x2_trans_x1 = get_perspective_transform(x1, x2)
- kornia.geometry.transform.get_perspective_transform3d(src, dst)[source]#
Calculate a 3d perspective transform from four pairs of the corresponding points.
The function calculates the matrix of a perspective transform so that:
\[\begin{split}\begin{bmatrix} t_{i}x_{i}^{'} \\ t_{i}y_{i}^{'} \\ t_{i}z_{i}^{'} \\ t_{i} \\ \end{bmatrix} = \textbf{map_matrix} \cdot \begin{bmatrix} x_{i} \\ y_{i} \\ z_{i} \\ 1 \\ \end{bmatrix}\end{split}\]where
\[dst(i) = (x_{i}^{'},y_{i}^{'},z_{i}^{'}), src(i) = (x_{i}, y_{i}, z_{i}), i = 0,1,2,5,7\]Concrete math is as below:
\[\[ u_i =\frac{c_{00} * x_i + c_{01} * y_i + c_{02} * z_i + c_{03}} {c_{30} * x_i + c_{31} * y_i + c_{32} * z_i + c_{33}} \] \[ v_i =\frac{c_{10} * x_i + c_{11} * y_i + c_{12} * z_i + c_{13}} {c_{30} * x_i + c_{31} * y_i + c_{32} * z_i + c_{33}} \] \[ w_i =\frac{c_{20} * x_i + c_{21} * y_i + c_{22} * z_i + c_{23}} {c_{30} * x_i + c_{31} * y_i + c_{32} * z_i + c_{33}} \]\]\[\begin{split}\begin{pmatrix} x_0 & y_0 & z_0 & 1 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & -x_0*u_0 & -y_0*u_0 & -z_0 * u_0 \\ x_1 & y_1 & z_1 & 1 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & -x_1*u_1 & -y_1*u_1 & -z_1 * u_1 \\ x_2 & y_2 & z_2 & 1 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & -x_2*u_2 & -y_2*u_2 & -z_2 * u_2 \\ x_5 & y_5 & z_5 & 1 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & -x_5*u_5 & -y_5*u_5 & -z_5 * u_5 \\ x_7 & y_7 & z_7 & 1 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & -x_7*u_7 & -y_7*u_7 & -z_7 * u_7 \\ 0 & 0 & 0 & 0 & x_0 & y_0 & z_0 & 1 & 0 & 0 & 0 & 0 & -x_0*v_0 & -y_0*v_0 & -z_0 * v_0 \\ 0 & 0 & 0 & 0 & x_1 & y_1 & z_1 & 1 & 0 & 0 & 0 & 0 & -x_1*v_1 & -y_1*v_1 & -z_1 * v_1 \\ 0 & 0 & 0 & 0 & x_2 & y_2 & z_2 & 1 & 0 & 0 & 0 & 0 & -x_2*v_2 & -y_2*v_2 & -z_2 * v_2 \\ 0 & 0 & 0 & 0 & x_5 & y_5 & z_5 & 1 & 0 & 0 & 0 & 0 & -x_5*v_5 & -y_5*v_5 & -z_5 * v_5 \\ 0 & 0 & 0 & 0 & x_7 & y_7 & z_7 & 1 & 0 & 0 & 0 & 0 & -x_7*v_7 & -y_7*v_7 & -z_7 * v_7 \\ 0 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & x_0 & y_0 & z_0 & 1 & -x_0*w_0 & -y_0*w_0 & -z_0 * w_0 \\ 0 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & x_1 & y_1 & z_1 & 1 & -x_1*w_1 & -y_1*w_1 & -z_1 * w_1 \\ 0 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & x_2 & y_2 & z_2 & 1 & -x_2*w_2 & -y_2*w_2 & -z_2 * w_2 \\ 0 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & x_5 & y_5 & z_5 & 1 & -x_5*w_5 & -y_5*w_5 & -z_5 * w_5 \\ 0 & 0 & 0 & 0 & 0 & 0 & 0 & 0 & x_7 & y_7 & z_7 & 1 & -x_7*w_7 & -y_7*w_7 & -z_7 * w_7 \\ \end{pmatrix}\end{split}\]- Convention:
points:
(x, y, z), pixel centers, origin at the top-left of the first depth slice; shape \((B, 8, 3)\)returns the source→destination pixel homography \((B, 4, 4)\)
- Parameters:
- Return type:
- Returns:
the perspective transformation with shape \((B, 4, 4)\).
Note
This function is often used in conjunction with
warp_perspective3d().
- kornia.geometry.transform.get_projective_transform(center, angles, scales)[source]#
Calculate the projection matrix for a 3D rotation.
Warning
This API signature it is experimental and might suffer some changes in the future.
The function computes the projection matrix given the center and angles per axis.
- Convention:
centeris(x, y, z)in pixels, origin at the top-left of the first depth slice (z = 0)rotation follows the right-hand rule (see
kornia.geometry.conversions.axis_angle_to_rotation_matrix()); a positive rotation about +z is clockwise on screen (y-down image axes) — opposite ofget_rotation_matrix2d()returns the projection matrix \((B, 3, 4)\) in pixel coordinates
- Parameters:
center (
Tensor) – center of the rotation (x,y,z) in the source with shape \((B, 3)\).angles (
Tensor) – axis angle vector containing the rotation angles in degrees in the form of (rx, ry, rz) with shape \((B, 3)\). Internally it calls Rodrigues to compute the rotation matrix from axis-angle.scales (
Tensor) – scale factor for x-y-z-directions with shape \((B, 3)\).
- Return type:
- Returns:
the projection matrix of 3D rotation with shape \((B, 3, 4)\).
Note
This function is often used in conjunction with
warp_affine3d().
- kornia.geometry.transform.get_rotation_matrix2d(center, angle, scale)[source]#
Calculate an affine matrix of 2D rotation.
The function calculates the following matrix:
\[\begin{split}\begin{bmatrix} \alpha & \beta & (1 - \alpha) \cdot \text{x} - \beta \cdot \text{y} \\ -\beta & \alpha & \beta \cdot \text{x} + (1 - \alpha) \cdot \text{y} \end{bmatrix}\end{split}\]where
\[\begin{split}\alpha = \text{scale} \cdot torch.cos(\text{angle}) \\ \beta = \text{scale} \cdot torch.sin(\text{angle})\end{split}\]The transformation maps the rotation center to itself If this is not the target, adjust the shift.
- Convention:
centeris(x, y)in pixels, origin at top-leftpositive
anglerotates counter-clockwise as displayed (y-down image axes)returns \((B, 2, 3)\) affine matrix in pixel coordinates
- Parameters:
center (
Tensor) – center of the rotation in the source image with shape \((B, 2)\).angle (
Tensor) – rotation angle in degrees. Positive values mean counter-clockwise rotation (the coordinate origin is assumed to be the top-left corner) with shape \((B)\).scale (
Tensor) – scale factor for x, y scaling with shape \((B, 2)\).
- Return type:
- Returns:
the affine matrix of 2D rotation with shape \((B, 2, 3)\).
Example
>>> center = torch.zeros(1, 2)
>>> scale = torch.ones((1, 2))
>>> angle = 45. * torch.ones(1)
>>> get_rotation_matrix2d(center, angle, scale)
tensor([[[ 0.7071,  0.7071,  0.0000],
         [-0.7071,  0.7071,  0.0000]]])
Note
This function is often used in conjunction with
warp_affine().
- kornia.geometry.transform.get_translation_matrix2d(translations)[source]#
Compose translation matrix from the components.
- Convention:
translationsis(dx, dy)in pixels; returns \((B, 3, 3)\) affine matrix in pixel coordinates
- Parameters:
translations (
Tensor) – torch.Tensor containing the translation vector with shape \((B, 2)\).- Return type:
- Returns:
the affine transformation matrix \((B, 3, 3)\).
Note
This function is often used in conjunction with
warp_affine(),warp_perspective().
- kornia.geometry.transform.get_shear_matrix2d(center, sx=None, sy=None)[source]#
Compose shear matrix Bx3x3 from the components.
Note: Ordered shearing, shear x-axis then y-axis.
\[\begin{split}\begin{bmatrix} 1 & b \\ a & ab + 1 \\ \end{bmatrix}\end{split}\]- Convention:
centeris(x, y)in pixels, origin at top-leftreturns \((B, 3, 3)\) affine matrix in pixel coordinates
- Parameters:
- Return type:
- Returns:
params to be passed to the affine transformation with shape \((B, 3, 3)\).
Examples
>>> rng = torch.manual_seed(0)
>>> sx = torch.randn(1)
>>> sx
tensor([1.5410])
>>> center = torch.tensor([[0., 0.]])  # Bx2
>>> get_shear_matrix2d(center, sx=sx)
tensor([[[  1.0000, -33.5468,   0.0000],
         [ -0.0000,   1.0000,   0.0000],
         [  0.0000,   0.0000,   1.0000]]])
Note
This function is often used in conjunction with
warp_affine(),warp_perspective().
- kornia.geometry.transform.get_shear_matrix3d(center, sxy=None, sxz=None, syx=None, syz=None, szx=None, szy=None)[source]#
Compose shear matrix Bx4x4 from the components.
Note: Ordered shearing, shear x-axis then y-axis then z-axis.
\[\begin{split}\begin{bmatrix} 1 & o & r & oy + rz \\ m & p & s & mx + py + sz -y \\ n & q & t & nx + qy + tz -z \\ 0 & 0 & 0 & 1 \\ \end{bmatrix} Where: m = S_{xy} n = S_{xz} o = S_{yx} p = S_{xy}S_{yx} + 1 q = S_{xz}S_{yx} + S_{yz} r = S_{zx} + S_{yx}S_{zy} s = S_{xy}S_{zx} + (S_{xy}S_{yx} + 1)S_{zy} t = S_{xz}S_{zx} + (S_{xz}S_{yx} + S_{yz})S_{zy} + 1\end{split}\]- Convention:
centeris(x, y, z)in pixels, origin at the top-left of the first depth slice (z = 0)returns \((B, 4, 4)\) affine matrix in pixel coordinates
- Parameters:
center (
Tensor) – shearing center coordinates of (x, y, z).sxy (
Optional[Tensor], optional) – shearing angle along x axis, towards y plane in radiants. Default:Nonesxz (
Optional[Tensor], optional) – shearing angle along x axis, towards z plane in radiants. Default:Nonesyx (
Optional[Tensor], optional) – shearing angle along y axis, towards x plane in radiants. Default:Nonesyz (
Optional[Tensor], optional) – shearing angle along y axis, towards z plane in radiants. Default:Noneszx (
Optional[Tensor], optional) – shearing angle along z axis, towards x plane in radiants. Default:Noneszy (
Optional[Tensor], optional) – shearing angle along z axis, towards y plane in radiants. Default:None
- Return type:
- Returns:
params to be passed to the affine transformation.
Examples
>>> rng = torch.manual_seed(0)
>>> sxy, sxz, syx, syz = torch.randn(4, 1)
>>> sxy, sxz, syx, syz
(tensor([1.5410]), tensor([-0.2934]), tensor([-2.1788]), tensor([0.5684]))
>>> center = torch.tensor([[0., 0., 0.]])  # Bx3
>>> get_shear_matrix3d(center, sxy=sxy, sxz=sxz, syx=syx, syz=syz)
tensor([[[  1.0000,  -1.4369,   0.0000,   0.0000],
         [-33.5468,  49.2039,   0.0000,   0.0000],
         [  0.3022,  -1.0729,   1.0000,   0.0000],
         [  0.0000,   0.0000,   0.0000,   1.0000]]])
Note
This function is often used in conjunction with
warp_perspective3d().
- kornia.geometry.transform.get_affine_matrix2d(translations, center, scale, angle, sx=None, sy=None)[source]#
Compose affine matrix from the components.
- Convention:
centeris(x, y)in pixels, origin at top-leftpositive
anglerotates clockwise as displayed — this function negatesanglebefore delegating toget_rotation_matrix2d(), whose convention is CCW-positivereturns \((B, 3, 3)\) affine matrix in pixel coordinates
- Parameters:
translations (
Tensor) – torch.Tensor containing the translation vector with shape \((B, 2)\).center (
Tensor) – torch.Tensor containing the center vector with shape \((B, 2)\).scale (
Tensor) – torch.Tensor containing the scale factor with shape \((B, 2)\).angle (
Tensor) – torch.Tensor of angles in degrees \((B)\).sx (
Optional[Tensor], optional) – torch.Tensor containing the shear factor in the x-direction with shape \((B)\). Default:Nonesy (
Optional[Tensor], optional) – torch.Tensor containing the shear factor in the y-direction with shape \((B)\). Default:None
- Return type:
- Returns:
the affine transformation matrix \((B, 3, 3)\).
Note
This function is often used in conjunction with
warp_affine(),warp_perspective().
- kornia.geometry.transform.get_affine_matrix3d(translations, center, scale, angles, sxy=None, sxz=None, syx=None, syz=None, szx=None, szy=None)[source]#
Compose 3d affine matrix from the components.
- Convention:
centeris(x, y, z)in pixels, origin at the top-left of the first depth slice (z = 0)anglesare negated before delegating toget_projective_transform(), whose own rotation convention follows the right-hand rule (seekornia.geometry.conversions.axis_angle_to_rotation_matrix())returns \((B, 4, 4)\) affine matrix in pixel coordinates
- Parameters:
translations (
Tensor) – torch.Tensor containing the translation vector (dx,dy,dz) with shape \((B, 3)\).center (
Tensor) – torch.Tensor containing the center vector (x,y,z) with shape \((B, 3)\).scale (
Tensor) – torch.Tensor containing the scale factor with shape \((B)\).angles (
Tensor) – axis angle vector containing the rotation angles in degrees in the form of (rx, ry, rz) with shape \((B, 3)\). Internally it calls Rodrigues to compute the rotation matrix from axis-angle.sxy (
Optional[Tensor], optional) – torch.Tensor containing the shear factor in the xy-direction with shape \((B)\). Default:Nonesxz (
Optional[Tensor], optional) – torch.Tensor containing the shear factor in the xz-direction with shape \((B)\). Default:Nonesyx (
Optional[Tensor], optional) – torch.Tensor containing the shear factor in the yx-direction with shape \((B)\). Default:Nonesyz (
Optional[Tensor], optional) – torch.Tensor containing the shear factor in the yz-direction with shape \((B)\). Default:Noneszx (
Optional[Tensor], optional) – torch.Tensor containing the shear factor in the zx-direction with shape \((B)\). Default:Noneszy (
Optional[Tensor], optional) – torch.Tensor containing the shear factor in the zy-direction with shape \((B)\). Default:None
- Return type:
- Returns:
the 3d affine transformation matrix \((B, 4, 4)\).
Note
This function is often used in conjunction with
warp_perspective3d().
- kornia.geometry.transform.invert_affine_transform(matrix)[source]#
Invert an affine transformation.
The function computes an inverse affine transformation represented by 2x3 matrix:
\[\begin{split}\begin{bmatrix} a_{11} & a_{12} & b_{1} \\ a_{21} & a_{22} & b_{2} \\ \end{bmatrix}\end{split}\]The result is also a 2x3 matrix of the same type as M.
- Convention:
matrixis a \((B, 2, 3)\) affine transform in any coordinate convention (pixel or normalized) — pure matrix inversion; the result stays in the input’s convention
- Parameters:
matrix (
Tensor) – original affine transform. The torch.Tensor must be in the shape of \((B, 2, 3)\).- Return type:
- Returns:
the reverse affine transform with shape \((B, 2, 3)\).
Note
This function is often used in conjunction with
warp_affine().
- kornia.geometry.transform.projection_from_Rt(rmat, tvec)[source]#
Compute the projection matrix from Rotation and translation.
Warning
This API signature it is experimental and might suffer some changes in the future.
Concatenates the batch of rotations and translations such that \(P = [R | t]\).
- Convention:
returns the concatenation \([R | t]\) with shape \((*, 3, 4)\)
- kornia.geometry.transform.get_tps_transform(points_src, points_dst)[source]#
Compute the TPS transform parameters that warp source points to target points.
The input to this function is a torch.Tensor of \((x, y)\) source points \((B, N, 2)\) and a corresponding torch.Tensor of target \((x, y)\) points \((B, N, 2)\).
- Convention:
points_src/points_dst: \((B, N, 2)\) in(x, y)order, in whatever coordinate frame the caller supplies; no normalization is appliedreturns kernel weights \((B, N, 2)\) and affine weights \((B, 3, 2)\); the identity mapping gives zero kernel weights and an identity affine up to solver round-off
the tensor passed as the second argument is the
kernel_centersthat the warp function must receive with these weights.warp_points_tps()is composed in the natural(points_src, points_dst)order;warp_image_tps()samples from output space back into input space, so it is composed reversed, with both point sets in the normalized frame given in its Convention block:kernel_weights, affine_weights = get_tps_transform(points_dst, points_src) warped = warp_image_tps(image, kernel_centers=points_src, kernel_weights=kernel_weights, affine_weights=affine_weights)
- Parameters:
- Return type:
- Returns:
- \((B, N, 2)\) torch.Tensor of kernel weights and \((B, 3, 2)\)
torch.Tensor of affine weights. The last dimension contains the x-transform and y-transform weights as separate columns.
Example
>>> points_src = torch.rand(1, 5, 2)
>>> points_dst = torch.rand(1, 5, 2)
>>> kernel_weights, affine_weights = get_tps_transform(points_src, points_dst)
Note
This function is often used in conjunction with
warp_points_tps(),warp_image_tps().
Crop operators#
- kornia.geometry.transform.crop_by_indices(input_tensor, src_box, size=None, interpolation='bilinear', align_corners=None, antialias=False, shape_compensation='resize')[source]#
Crop tensors with naive indices.
- Convention:
input: \((B, C, H, W)\);
sizeis(h, w)if given, else inferred fromsrc_boxsrc_box: \((B, 4, 2)\) corner points in(x, y)order top-left, top-right, bottom-right, bottom-left — same convention ascrop_and_resize()unlike the other crop operators in this module:
interpolation=(notmode=),align_corners=Noneby default (notTrue), and anantialias=Falseoptionshape_compensation('resize'by default) applies whenever the cropped slice does not matchsize, whether or notsrc_boxis identical across the batch — each row’s output depends only on its own box. Graph export is the exception: it always resamples (see the note below)
- Parameters:
input_tensor (
Tensor) – the 2D image torch.Tensor with shape (B, C, H, W).src_box (
Tensor) – a torch.Tensor with shape (B, 4, 2) containing the coordinates of the bounding boxes to be extracted. The torch.Tensor must have the shape of Bx4x2, where each box is defined in the clockwise order: top-left, top-right, bottom-right and bottom-left. The coordinates must be in x, y order.size (
Optional[Tuple[int,int]], optional) – output size. An auto resize or F.pad will be performed according toshape_compensationif the cropped slice sizes are not exactly align size. If None, will auto-infer from src_box. Default:Noneinterpolation (
str, optional) – algorithm used for upsampling:'nearest'|'linear'|'bilinear'| ‘bicubic’ | ‘trilinear’ | ‘area’. Default:"bilinear"align_corners (
Optional[bool], optional) – interpolation flag. Default:Noneantialias (
bool, optional) – if True, then image will be filtered with Gaussian before downscaling. No effect for upscaling. Default:Falseshape_compensation (
str, optional) – if the cropped slice sizes are not exactly align size, the image can either be padded or resized. Default:"resize"
- Return type:
- Returns:
The cropped torch.Tensor with shape \((B, C, h, w)\), where \((h, w)\) is
sizeif given, otherwise the shape inferred fromsrc_box.
Note
Under graph export (
torch.export.export()/torch.onnx.export()) the box coordinates cannot be read back to Python, so the crop is captured as the same warp ascrop_and_resize()(align_corners=True), which keeps the box coordinates dynamic. This needssize: a box that is exactlysizepixels (whatRandomCropandCenterCrop2Dproduce) is reproduced exactly, any other box is resampled tosizewithalign_corners=Trueregardless ofshape_compensationandalign_corners. Withoutsizethe eager path is kept: it reads the box coordinates back to Python, which breaks the graph undertorch.compile()and is rejected bytorch.exportas data-dependent.
- kornia.geometry.transform.crop_by_boxes(input_tensor, src_box, dst_box, mode='bilinear', padding_mode='zeros', align_corners=True, validate_boxes=True)[source]#
Perform crop transform on 2D images (4D torch.Tensor) given two bounding boxes.
Given an input torch.Tensor, this function selected the interested areas by the provided bounding boxes (src_box). Then the selected areas would be fitted into the targeted bounding boxes (dst_box) by a perspective transformation. So far, the ragged torch.Tensor is not supported by PyTorch right now. This function hereby requires the bounding boxes in a batch must be rectangles with same width and height.
- Convention:
input: \((B, C, H, W)\)
src_box/dst_box: \((B, 4, 2)\) corner points in(x, y)order top-left, top-right, bottom-right, bottom-left — same convention ascrop_and_resize();dst_boxdetermines the output resolutiona single box (batch size 1) broadcasts over a batch of images, but a single image does not broadcast over a batch of boxes
- Parameters:
input_tensor (
Tensor) – the 2D image torch.Tensor with shape (B, C, H, W).src_box (
Tensor) – a torch.Tensor with shape (B, 4, 2) containing the coordinates of the bounding boxes to be extracted. The torch.Tensor must have the shape of Bx4x2, where each box is defined in the clockwise order: top-left, top-right, bottom-right and bottom-left. The coordinates must be in x, y order.dst_box (
Tensor) – a torch.Tensor with shape (B, 4, 2) containing the coordinates of the bounding boxes to be placed. The torch.Tensor must have the shape of Bx4x2, where each box is defined in the clockwise order: top-left, top-right, bottom-right and bottom-left. The coordinates must be in x, y order.mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – mode for grid_generation. Default:Truevalidate_boxes (
bool, optional) – flag to perform validation on boxes. Default:True
- Returns:
the output torch.tensor with patches.
- Return type:
Examples
>>> input = torch.arange(16, dtype=torch.float32).reshape((1, 1, 4, 4))
>>> src_box = torch.tensor([[
...     [1., 1.],
...     [2., 1.],
...     [2., 2.],
...     [1., 2.],
... ]])  # 1x4x2
>>> dst_box = torch.tensor([[
...     [0., 0.],
...     [1., 0.],
...     [1., 1.],
...     [0., 1.],
... ]])  # 1x4x2
>>> crop_by_boxes(input, src_box, dst_box, align_corners=True)
tensor([[[[ 5.0000,  6.0000],
          [ 9.0000, 10.0000]]]])
- kornia.geometry.transform.crop_by_transform_mat(input_tensor, transform, out_size, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Perform crop transform on 2D images (4D torch.Tensor) given a perspective transformation matrix.
- Convention:
input: \((B, C, H, W)\);
out_sizeis(h, w)transformis the source→destination pixel transform, accepted as either \((B, 2, 3)\) affine or \((B, 3, 3)\) homogeneous; dispatch is by shape — \((B, 2, 3)\) takes the cheaperwarp_affine()path, while \((B, 3, 3)\) takeswarp_perspective()and uses the full matrix, so a non-trivial third (projective) row changes the output; anout_sizedimension of1is handled like any other size
- Parameters:
input_tensor (
Tensor) – the 2D image torch.Tensor with shape (B, C, H, W).transform (
Tensor) – a perspective transformation matrix with shape (B, 3, 3), or an affine matrix with shape (B, 2, 3) that takes the cheaper warp_affine path.out_size (
Tuple[int,int]) – size of the output image (height, width).mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (str) – padding mode for outside grid values
'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – mode for grid_generation. Default:True
- Return type:
- Returns:
the output torch.Tensor with patches.
- kornia.geometry.transform.center_crop(input_tensor, size, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Crop the 2D images (4D torch.Tensor) from the center.
- Convention:
input: \((B, C, H, W)\) (strictly 4D — no unbatched
(C, H, W)/(H, W)input is accepted);sizeis(h, w)
- Parameters:
input_tensor (
Tensor) – the 2D image torch.Tensor with shape (B, C, H, W).size (
Tuple[int,int]) – a tuple with the expected height and width of the output patch.mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – mode for grid_generation. Default:True
- Return type:
- Returns:
the output torch.Tensor with patches.
Examples
>>> input = torch.tensor([[[
...     [1., 2., 3., 4.],
...     [5., 6., 7., 8.],
...     [9., 10., 11., 12.],
...     [13., 14., 15., 16.],
...  ]]])
>>> center_crop(input, (2, 4), mode='nearest', align_corners=True)
tensor([[[[ 5.,  6.,  7.,  8.],
          [ 9., 10., 11., 12.]]]])
- kornia.geometry.transform.crop_and_resize(input_tensor, boxes, size, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Extract crops from 2D images (4D torch.Tensor) and resize given a bounding box.
- Convention:
See Conventions & Pitfalls for the
align_cornersdefaults and sampling rules.input: \((B, C, H, W)\);
sizeis(h, w)boxes: \((B, 4, 2)\) corner points in(x, y)order top-left, top-right, bottom-right, bottom-left; coordinates are inclusive pixel positions (box(1, 1)..``(2, 2)`` selects a \(2 \times 2\) pixel block), origin at top-left
- Parameters:
input_tensor (
Tensor) – the 2D image torch.Tensor with shape (B, C, H, W).boxes (
Tensor) – a torch.Tensor containing the coordinates of the bounding boxes to be extracted. The torch.Tensor must have the shape of Bx4x2, where each box is defined in the following (clockwise) order: top-left, top-right, bottom-right and bottom-left. The coordinates must be in the x, y order. The coordinates would compose a rectangle with a shape of (N1, N2).size (
Tuple[int,int]) – a tuple with the height and width that will be used to resize the extracted patches.mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – mode for grid_generation. Default:True
- Returns:
torch.tensor containing the patches with shape BxCxN1xN2.
- Return type:
Example
>>> input = torch.tensor([[[
...     [1., 2., 3., 4.],
...     [5., 6., 7., 8.],
...     [9., 10., 11., 12.],
...     [13., 14., 15., 16.],
... ]]])
>>> boxes = torch.tensor([[
...     [1., 1.],
...     [2., 1.],
...     [2., 2.],
...     [1., 2.],
... ]])  # 1x4x2
>>> crop_and_resize(input, boxes, (2, 2), mode='nearest', align_corners=True)
tensor([[[[ 6.,  7.],
          [10., 11.]]]])
Crop operators (3D)#
- kornia.geometry.transform.crop_by_boxes3d(tensor, src_box, dst_box, interpolation='bilinear', align_corners=False)[source]#
Perform crop transform on 3D volumes (5D tensor) by bounding boxes.
Given an input tensor, this function selected the interested areas by the provided bounding boxes (src_box). Then the selected areas would be fitted into the targeted bounding boxes (dst_box) by a perspective transformation. So far, the ragged tensor is not supported by PyTorch right now. This function hereby requires the bounding boxes in a batch must be rectangles with same width, height and depth.
- Convention:
input: \((B, C, D, H, W)\)
src_box/dst_box: \((B, 8, 3)\) corner points in(x, y, z)order, front face then back face, each face top-left, top-right, bottom-right, bottom-left — same convention ascrop_and_resize3d();dst_boxdetermines the output resolutionalign_corners:
Falseby default
- Parameters:
tensor (
Tensor) – the 3D volume tensor with shape (B, C, D, H, W).src_box (
Tensor) – a tensor with shape (B, 8, 3) containing the coordinates of the bounding boxes to be extracted. The tensor must have the shape of Bx8x3, where each box is defined in the clockwise order: front-top-left, front-top-right, front-bottom-right, front-bottom-left, back-top-left, back-top-right, back-bottom-right, back-bottom-left. The coordinates must be in x, y, z order.dst_box (
Tensor) – a tensor with shape (B, 8, 3) containing the coordinates of the bounding boxes to be placed. The tensor must have the shape of Bx8x3, where each box is defined in the clockwise order: front-top-left, front-top-right, front-bottom-right, front-bottom-left, back-top-left, back-top-right, back-bottom-right, back-bottom-left. The coordinates must be in x, y, z order.interpolation (
str, optional) – Interpolation flag. Default:"bilinear"align_corners (
bool, optional) – mode for grid_generation. Default:False
- Return type:
- Returns:
the output tensor with patches.
Examples
>>> input = torch.tensor([[[
...         [[ 0.,  1.,  2.,  3.],
...          [ 4.,  5.,  6.,  7.],
...          [ 8.,  9., 10., 11.],
...          [12., 13., 14., 15.]],
...         [[16., 17., 18., 19.],
...          [20., 21., 22., 23.],
...          [24., 25., 26., 27.],
...          [28., 29., 30., 31.]],
...         [[32., 33., 34., 35.],
...          [36., 37., 38., 39.],
...          [40., 41., 42., 43.],
...          [44., 45., 46., 47.]]]]])
>>> src_box = torch.tensor([[
...     [1., 1., 1.],
...     [3., 1., 1.],
...     [3., 3., 1.],
...     [1., 3., 1.],
...     [1., 1., 2.],
...     [3., 1., 2.],
...     [3., 3., 2.],
...     [1., 3., 2.],
... ]])  # 1x8x3
>>> dst_box = torch.tensor([[
...     [0., 0., 0.],
...     [2., 0., 0.],
...     [2., 2., 0.],
...     [0., 2., 0.],
...     [0., 0., 1.],
...     [2., 0., 1.],
...     [2., 2., 1.],
...     [0., 2., 1.],
... ]])  # 1x8x3
>>> crop_by_boxes3d(input, src_box, dst_box, interpolation='nearest', align_corners=True)
tensor([[[[[21., 22., 23.],
           [25., 26., 27.],
           [29., 30., 31.]],

          [[37., 38., 39.],
           [41., 42., 43.],
           [45., 46., 47.]]]]])
- kornia.geometry.transform.crop_by_transform_mat3d(tensor, transform, out_size, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Perform crop transform on 3D volumes (5D tensor) given a perspective transformation matrix.
- Convention:
input: \((B, C, D, H, W)\);
out_sizeis(d, h, w)transformis the source→destination pixel transform, accepted as either \((B, 3, 4)\) affine or \((B, 4, 4)\) homogeneous; only the top three rows are used, so a projective last row is ignored (unlike the 2Dcrop_by_transform_mat())align_corners:
Trueby default
- Parameters:
tensor (
Tensor) – the 3D volume tensor with shape (B, C, D, H, W).transform (
Tensor) – the source->destination pixel transform, either affine with shape (B, 3, 4) or homogeneous with shape (B, 4, 4).out_size (
Tuple[int,int,int]) – size of the output image (depth, height, width).mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – mode for grid_generation. Default:True
- Return type:
- Returns:
the output tensor with patches.
- kornia.geometry.transform.center_crop3d(tensor, size, interpolation='bilinear', align_corners=True)[source]#
Crop the 3D volumes (5D tensor) at the center.
- Convention:
input: \((B, C, D, H, W)\);
sizeis(d, h, w)align_corners:
Trueby default
- Parameters:
tensor (
Tensor) – the 3D volume tensor with shape (B, C, D, H, W).size (
Tuple[int,int,int]) – a tuple with the expected depth, height and width of the output patch.interpolation (
str, optional) – Interpolation flag. Default:"bilinear"align_corners (
bool, optional) – mode for grid_generation. Default:True
- Return type:
- Returns:
the output tensor with patches.
Examples
>>> input = torch.arange(64, dtype=torch.float32).view(1, 1, 4, 4, 4)
>>> input
tensor([[[[[ 0.,  1.,  2.,  3.],
           [ 4.,  5.,  6.,  7.],
           [ 8.,  9., 10., 11.],
           [12., 13., 14., 15.]],

          [[16., 17., 18., 19.],
           [20., 21., 22., 23.],
           [24., 25., 26., 27.],
           [28., 29., 30., 31.]],

          [[32., 33., 34., 35.],
           [36., 37., 38., 39.],
           [40., 41., 42., 43.],
           [44., 45., 46., 47.]],

          [[48., 49., 50., 51.],
           [52., 53., 54., 55.],
           [56., 57., 58., 59.],
           [60., 61., 62., 63.]]]]])
>>> center_crop3d(input, (2, 2, 2), align_corners=True)
tensor([[[[[21.0000, 22.0000],
           [25.0000, 26.0000]],

          [[37.0000, 38.0000],
           [41.0000, 42.0000]]]]])
- kornia.geometry.transform.crop_and_resize3d(tensor, boxes, size, interpolation='bilinear', align_corners=False)[source]#
Extract crops from 3D volumes (5D tensor) and resize them.
- Convention:
input: \((B, C, D, H, W)\);
sizeis(d, h, w)boxes: \((B, 8, 3)\) corner points in(x, y, z)order, front face then back face, each face top-left, top-right, bottom-right, bottom-left — same(x, y)/inclusive-pixel convention ascrop_and_resize(), withzanchored at the top-left of the first depth slice (z = 0); reproducing the exact integer-voxel slice requiresalign_corners=True— the defaultFalseinterpolates insteadalign_corners:
Falseby default
- Parameters:
tensor (
Tensor) – the 3D volume tensor with shape (B, C, D, H, W).boxes (
Tensor) – a tensor with shape (B, 8, 3) containing the coordinates of the bounding boxes to be extracted. The tensor must have the shape of Bx8x3, where each box is defined in the clockwise order: front-top-left, front-top-right, front-bottom-right, front-bottom-left, back-top-left, back-top-right, back-bottom-right, back-bottom-left. The coordinates must be in x, y, z order.size (
Tuple[int,int,int]) – a tuple with the depth, height and width that will be used to resize the extracted patches.interpolation (
str, optional) – Interpolation flag. Default:"bilinear"align_corners (
bool, optional) – mode for grid_generation. Default:False
- Return type:
- Returns:
tensor containing the patches with shape (Bx)CxN1xN2xN3.
Example
>>> input = torch.arange(64, dtype=torch.float32).view(1, 1, 4, 4, 4)
>>> input
tensor([[[[[ 0.,  1.,  2.,  3.],
           [ 4.,  5.,  6.,  7.],
           [ 8.,  9., 10., 11.],
           [12., 13., 14., 15.]],

          [[16., 17., 18., 19.],
           [20., 21., 22., 23.],
           [24., 25., 26., 27.],
           [28., 29., 30., 31.]],

          [[32., 33., 34., 35.],
           [36., 37., 38., 39.],
           [40., 41., 42., 43.],
           [44., 45., 46., 47.]],

          [[48., 49., 50., 51.],
           [52., 53., 54., 55.],
           [56., 57., 58., 59.],
           [60., 61., 62., 63.]]]]])
>>> boxes = torch.tensor([[
...     [1., 1., 1.],
...     [3., 1., 1.],
...     [3., 3., 1.],
...     [1., 3., 1.],
...     [1., 1., 2.],
...     [3., 1., 2.],
...     [3., 3., 2.],
...     [1., 3., 2.],
... ]])  # 1x8x3
>>> crop_and_resize3d(input, boxes, (2, 2, 2), align_corners=True)
tensor([[[[[21.0000, 23.0000],
           [29.0000, 31.0000]],

          [[37.0000, 39.0000],
           [45.0000, 47.0000]]]]])
Modules#
- class kornia.geometry.transform.Rotate(angle, center=None, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Rotate the tensor anti-clockwise about the centre.
- Convention:
See the convention block of
rotate().
- Parameters:
angle (
Tensor) – The angle through which to rotate. The tensor must have a shape of (B), where B is batch size.center (
Optional[Tensor], optional) – The center through which to rotate. The tensor must have a shape of (B, 2), where B is batch size and last dimension contains cx and cy. Default:Nonemode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:True
- Returns:
The rotated tensor with the same shape as the input.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> angle = torch.tensor([90.])
>>> out = Rotate(angle)(img)
>>> print(out.shape)
torch.Size([1, 3, 4, 4])
- class kornia.geometry.transform.Translate(translation, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Translate the tensor in pixel units.
- Convention:
See the convention block of
translate().
- Parameters:
translation (
Tensor) – tensor containing the amount of pixels to translate in the x and y direction. The tensor must have a shape of (B, 2), where B is batch size, last dimension contains dx dy.mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:True
- Returns:
The translated tensor with the same shape as the input.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> translation = torch.tensor([[1., 0.]])
>>> out = Translate(translation)(img)
>>> print(out.shape)
torch.Size([1, 3, 4, 4])
- class kornia.geometry.transform.Scale(scale_factor, center=None, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Scale the tensor by a factor.
- Convention:
See the convention block of
scale().
- Parameters:
scale_factor (
Tensor) – The scale factor apply. The tensor must have a shape of (B) or (B, 2), where B is batch size. If (B), isotropic scaling will perform. If (B, 2), x-y-direction specific scaling will perform.center (
Optional[Tensor], optional) – The center through which to scale. The tensor must have a shape of (B, 2), where B is batch size and last dimension contains cx and cy. Default:Nonemode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:True
- Returns:
The scaled tensor with the same shape as the input.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> scale_factor = torch.tensor([[2., 2.]])
>>> out = Scale(scale_factor)(img)
>>> print(out.shape)
torch.Size([1, 3, 4, 4])
- class kornia.geometry.transform.Shear(shear, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Shear the tensor.
- Convention:
- Parameters:
shear (
Tensor) – tensor containing the angle to shear in the x and y direction. The tensor must have a shape of (B, 2), where B is batch size, last dimension contains shx shy.mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:True
- Returns:
The skewed tensor with the same shape as the input.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> shear_factor = torch.tensor([[0.5, 0.0]])
>>> out = Shear(shear_factor)(img)
>>> print(out.shape)
torch.Size([1, 3, 4, 4])
- class kornia.geometry.transform.PyrDown(border_type='reflect', align_corners=False, factor=2.0)[source]#
Blur a torch.Tensor and downsamples it.
- Convention:
See the convention block of
pyrdown().
- Parameters:
border_type (
str, optional) – the padding mode to be applied before convolving. The expected modes are:'constant','reflect','replicate'or'circular'. Default:"reflect"align_corners (
bool, optional) – interpolation flag. Default:Falsefactor (
float, optional) – the downsampling factor Default:2.0
- Returns:
the downsampled torch.Tensor.
- Shape:
Input: \((B, C, H, W)\)
Output: \((B, C, H / 2, W / 2)\)
Examples
>>> input = torch.rand(1, 2, 4, 4)
>>> output = PyrDown()(input)  # 1x2x2x2
- class kornia.geometry.transform.PyrUp(border_type='reflect', align_corners=False)[source]#
Upsample a torch.Tensor and then blurs it.
- Convention:
See the convention block of
pyrup().
- Parameters:
- Returns:
the upsampled torch.Tensor.
- Shape:
Input: \((B, C, H, W)\)
Output: \((B, C, H * 2, W * 2)\)
Examples
>>> input = torch.rand(1, 2, 4, 4)
>>> output = PyrUp()(input)  # 1x2x8x8
- class kornia.geometry.transform.ScalePyramid(n_levels=3, init_sigma=1.6, min_size=15, double_image=False, extra_levels=3)[source]#
Create an scale pyramid of image, usually used for local feature detection.
Images are consequently smoothed with Gaussian blur and downscaled.
- Convention:
input: \((B, C, H, W)\)
forwardreturns(pyr, sigmas, pixel_dists), one entry per octave:pyr[o]is \((B, C, L, H_o, W_o)\) withL = n_levels + extra_levels, andsigmas[o]andpixel_dists[o]are \((B, L)\) nominal values (the targeted blur, not a measurement)sigmasis octave-relative: the blur in input pixels issigmas[o] * pixel_dists[o]an
init_sigmabelow the assumed input blur (0.5, or1.0withdouble_image=True) leaves the first level at that blur, and the octave is built and labelled from it, as ifinit_sigmawere the assumed input blurthe internal resizes use
align_corners=True; there is noalign_cornersparameter
- Parameters:
n_levels (
int, optional) – number of the levels in octave. Default:3init_sigma (
float, optional) – initial blur level. Default:1.6min_size (
int, optional) – the minimum size of the octave in pixels. Default:15double_image (
bool, optional) – add 2x upscaled image as 1st level of pyramid. OpenCV SIFT does this. Default:False
- Returns:
images 2nd output: sigmas (coefficients for scale conversion) 3rd output: pixelDists (coefficients for coordinate conversion)
- Return type:
1st output
- Shape:
Input: \((B, C, H, W)\)
Output 1st: \([(B, C, NL, H, W), (B, C, NL, H/2, W/2), ...]\)
Output 2nd: \([(B, NL), (B, NL), (B, NL), ...]\)
Output 3rd: \([(B, NL), (B, NL), (B, NL), ...]\)
Examples
>>> input = torch.rand(2, 4, 100, 100)
>>> sp, sigmas, pds = ScalePyramid(3, 15)(input)
- class kornia.geometry.transform.Hflip(*args, **kwargs)[source]#
Horizontally flip a torch.Tensor image or a batch of torch.Tensor images.
- Convention:
See the convention block of
hflip().
- Parameters:
input – input torch.Tensor.
- Returns:
The horizontally flipped image torch.Tensor.
Examples
>>> hflip = Hflip()
>>> input = torch.tensor([[[
...    [0., 0., 0.],
...    [0., 0., 0.],
...    [0., 1., 1.]
... ]]])
>>> hflip(input)
tensor([[[[0., 0., 0.],
          [0., 0., 0.],
          [1., 1., 0.]]]])
- class kornia.geometry.transform.Vflip(*args, **kwargs)[source]#
Vertically flip a torch.Tensor image or a batch of torch.Tensor images.
- Convention:
See the convention block of
vflip().
- Parameters:
input – input torch.Tensor.
- Returns:
The vertically flipped image torch.Tensor.
Examples
>>> vflip = Vflip()
>>> input = torch.tensor([[[
...    [0., 0., 0.],
...    [0., 0., 0.],
...    [0., 1., 1.]
... ]]])
>>> vflip(input)
tensor([[[[0., 1., 1.],
          [0., 0., 0.],
          [0., 0., 0.]]]])
- class kornia.geometry.transform.Rot180(*args, **kwargs)[source]#
Rotate a torch.Tensor image or a batch of torch.Tensor images 180 degrees.
- Convention:
See the convention block of
rot180().
- Parameters:
input – input torch.Tensor.
Examples
>>> rot180 = Rot180()
>>> input = torch.tensor([[[
...    [0., 0., 0.],
...    [0., 0., 0.],
...    [0., 1., 1.]
... ]]])
>>> rot180(input)
tensor([[[[1., 1., 0.],
          [0., 0., 0.],
          [0., 0., 0.]]]])
- class kornia.geometry.transform.Resize(size, interpolation='bilinear', align_corners=None, side='short', antialias=False)[source]#
Resize the input torch.Tensor to the given size.
- Convention:
See Conventions & Pitfalls for sampling and
align_cornersconventions. When resizing camera images, see camera and world conventions for matching intrinsics scaling.See the convention block of
resize().
- Parameters:
size (
Union[int,Tuple[int,int]]) – Desired output size. If size is a sequence like (h, w), output size will be matched to this. If size is an int, smaller edge of the image will be matched to this number. i.e, if height > width, then image will be rescaled to (size * height / width, size)interpolation (
str, optional) – algorithm used for upsampling:'nearest'|'linear'|'bilinear'| ‘bicubic’ | ‘trilinear’ | ‘area’. Default:"bilinear"align_corners (
Optional[bool], optional) – interpolation flag. Default:Noneside (
str, optional) – Corresponding side ifsizeis an integer. Can be one of'short','long','vert', or'horz'. Default:"short"antialias (
bool, optional) – if True, then image will be filtered with Gaussian before downscaling. No effect for upscaling. Default:False
- Returns:
The resized tensor with the shape of the given size.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> out = Resize((6, 8))(img)
>>> print(out.shape)
torch.Size([1, 3, 6, 8])
- class kornia.geometry.transform.Rescale(factor, interpolation='bilinear', align_corners=True, antialias=False)[source]#
Rescale the input torch.Tensor with the given factor.
- Convention:
- Parameters:
factor (
Union[float,Tuple[float,float]]) – Desired scaling factor as(factor_h, factor_w)— height first. If a single float, the value is used for both height and width (anintraisesTypeError).interpolation (
str, optional) – algorithm used for upsampling:'nearest'|'linear'|'bilinear'|'bicubic'|'trilinear'|'area'. Default:"bilinear"align_corners (
bool, optional) – interpolation flag. Default:Trueantialias (
bool, optional) – if True, then image will be filtered with Gaussian before downscaling. No effect for upscaling. Default:False
- Returns:
The rescaled tensor with the shape according to the given factor.
Example
>>> img = torch.rand(1, 3, 4, 4)
>>> out = Rescale((2, 3))(img)
>>> print(out.shape)
torch.Size([1, 3, 8, 12])
- class kornia.geometry.transform.Affine(angle=None, translation=None, scale_factor=None, shear=None, center=None, mode='bilinear', padding_mode='zeros', align_corners=True)[source]#
Apply multiple elementary affine transforms simultaneously.
- Convention:
See the convention block of
affine().
- Parameters:
angle (
Optional[Tensor], optional) – Angle in degrees for counter-clockwise rotation around the center. The tensor must have a shape of (B), where B is the batch size. Default:Nonetranslation (
Optional[Tensor], optional) – Amount of pixels for translation in x- and y-direction. The tensor must have a shape of (B, 2), where B is the batch size and the last dimension contains dx and dy. Default:Nonescale_factor (
Optional[Tensor], optional) – Factor for scaling. The tensor must have a shape of (B,2), where B is the batch size and the last dimension contains scale factors for x and y direction. Default:Noneshear (
Optional[Tensor], optional) – Factor for shearing in x- and y-direction around the center. The tensor must have a shape of (B, 2), where B is the batch size and the last dimension contains sx and sy. Default:Nonecenter (
Optional[Tensor], optional) – Transformation center in pixels. The tensor must have a shape of (B, 2), where B is the batch size and the last dimension contains cx and cy. Defaults to the center of image to be transformed. Default:Nonemode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"align_corners (
bool, optional) – interpolation flag. Default:True
- Raises:
RuntimeError – If not one of
angle,translation,scale_factor, orshearis set.- Returns:
The transformed tensor with same shape as input.
Example
>>> img = torch.rand(1, 2, 3, 5)
>>> angle = 90. * torch.rand(1)
>>> out = Affine(angle)(img)
>>> print(out.shape)
torch.Size([1, 2, 3, 5])
- class kornia.geometry.transform.BaseWarper(height, width, *args, **kwargs)[source]#
Provide a base class for homography-based image warping.
- Convention:
subclasses receive
src_homo_dstas the destination→source homography
- class kornia.geometry.transform.HomographyWarper(height, width, mode='bilinear', padding_mode='zeros', normalized_coordinates=True, align_corners=False)[source]#
Warp tensors by homographies.
\[X_{src} = H_{src}^{\{dst\}} * X_{dst}\]- Convention:
See Conventions & Pitfalls for homography direction, normalized coordinates and sampling conventions.
See the convention block of
homography_warp().
- Parameters:
height (
int) – The height of the destination torch.Tensor.width (
int) – The width of the destination torch.Tensor.mode (
str, optional) – interpolation mode to calculate output values'bilinear'|'nearest'. Default:"bilinear"padding_mode (
str, optional) – padding mode for outside grid values'zeros'|'border'|'reflection'. Default:"zeros"normalized_coordinates (
bool, optional) – whether to use a grid with normalized coordinates. Default:Truealign_corners (
bool, optional) – interpolation flag. Default:False
- class kornia.geometry.transform.CenterCrop2D(size, align_corners=True, resample=Resample.BILINEAR.name, cropping_mode='slice')[source]#
Center crop the input torch.Tensor.
- Convention:
align_corners(andresample) only take effect whencropping_mode='resample'; the defaultcropping_mode='slice'performs integer-index slicing and ignores bothSee the convention block of
center_crop().
- Parameters:
size (
Union[int,Tuple[int,int]]) – Size (h, w) in pixels of the resized region or just one side.align_corners (
bool, optional) – interpolation flag. Default:Trueresample (
Union[str,int,Resample], optional) – Resampling mode. Default:Resample.BILINEAR.namecropping_mode (
str, optional) – Cropping mode, “resample” or “slice”. Default:"slice"
Note
For JIT, the cropping mode must be “resample”.
Image registration#
See also the image registration application page.
- class kornia.geometry.transform.image_registrator.BaseModel(*args, **kwargs)[source]#
Provide an abstract base class for image registration models.
- abstractmethod forward()[source]#
Return the transform that maps source coordinates toward target coordinates.
- Return type:
- Returns:
Transform matrix tensor for the current model state. Concrete models return the matrix shape required by their warp function.
- class kornia.geometry.transform.image_registrator.Homography[source]#
Homography geometric model to be used with ImageRegistrator for the optimization-based image registration.
- forward()[source]#
Single-batch homography”.
- Return type:
- Returns:
Homography matrix with shape \((1, 3, 3)\).
- class kornia.geometry.transform.image_registrator.ImageRegistrator(model_type='homography', optimizer=optim.Adam, loss_fn=F.l1_loss, pyramid_levels=5, lr=1e-3, num_iterations=100, tolerance=1e-4, warper=None, allow_shape_mismatch=False)[source]#
nn.Module, which performs optimization-based image registration.
- Parameters:
model_type (
Union[str,BaseModel], optional) – Geometrical model for registration. Can be string or nn.Module. Default:"homography"optimizer (
Type[Optimizer], optional) – optimizer class used for the optimization. Default:optim.Adamloss_fn (
Callable[...,Tensor], optional) – torch loss function. Default:F.l1_losspyramid_levels (
int, optional) – number of scale pyramid levels. Default:5lr (
float, optional) – learning rate for optimization. Default:1e-3num_iterations (
int, optional) – maximum number of iterations. Default:100tolerance (
float, optional) – stop optimizing if loss difference is less. default 1e-4. Default:1e-4warper (
Optional[Type[BaseWarper]], optional) – if model_type is not string, one needs to provide warper object. Default:None
Example
>>> from kornia.geometry import ImageRegistrator
>>> img_src = torch.rand(1, 1, 32, 32)
>>> img_dst = torch.rand(1, 1, 32, 32)
>>> registrator = ImageRegistrator('similarity')
>>> homo = registrator.register(img_src, img_dst)
- get_single_level_loss(img_src, img_dst, transform_model)[source]#
Warp img_src into img_dst with transform_model and returns loss.
- Return type:
- register(src_img, dst_img, verbose=False, output_intermediate_models=False)[source]#
Estimate the transformation which warps src_img into dst_img by gradient descent.
The shape of the tensors is not checked, because it may depend on the model, e.g. volume registration.
- Parameters:
- Return type:
- Returns:
the transformation between two images, shape depends on the model, typically [1x3x3] torch.Tensor for string model_types.
- class kornia.geometry.transform.image_registrator.Similarity(rotation=True, scale=True, shift=True)[source]#
Similarity geometric model to be used with ImageRegistrator module for the optimization-based image registration.
- Parameters:
- forward()[source]#
Single-batch similarity transform”.
- Return type:
- Returns:
Similarity with shape \((1, 3, 3)\)